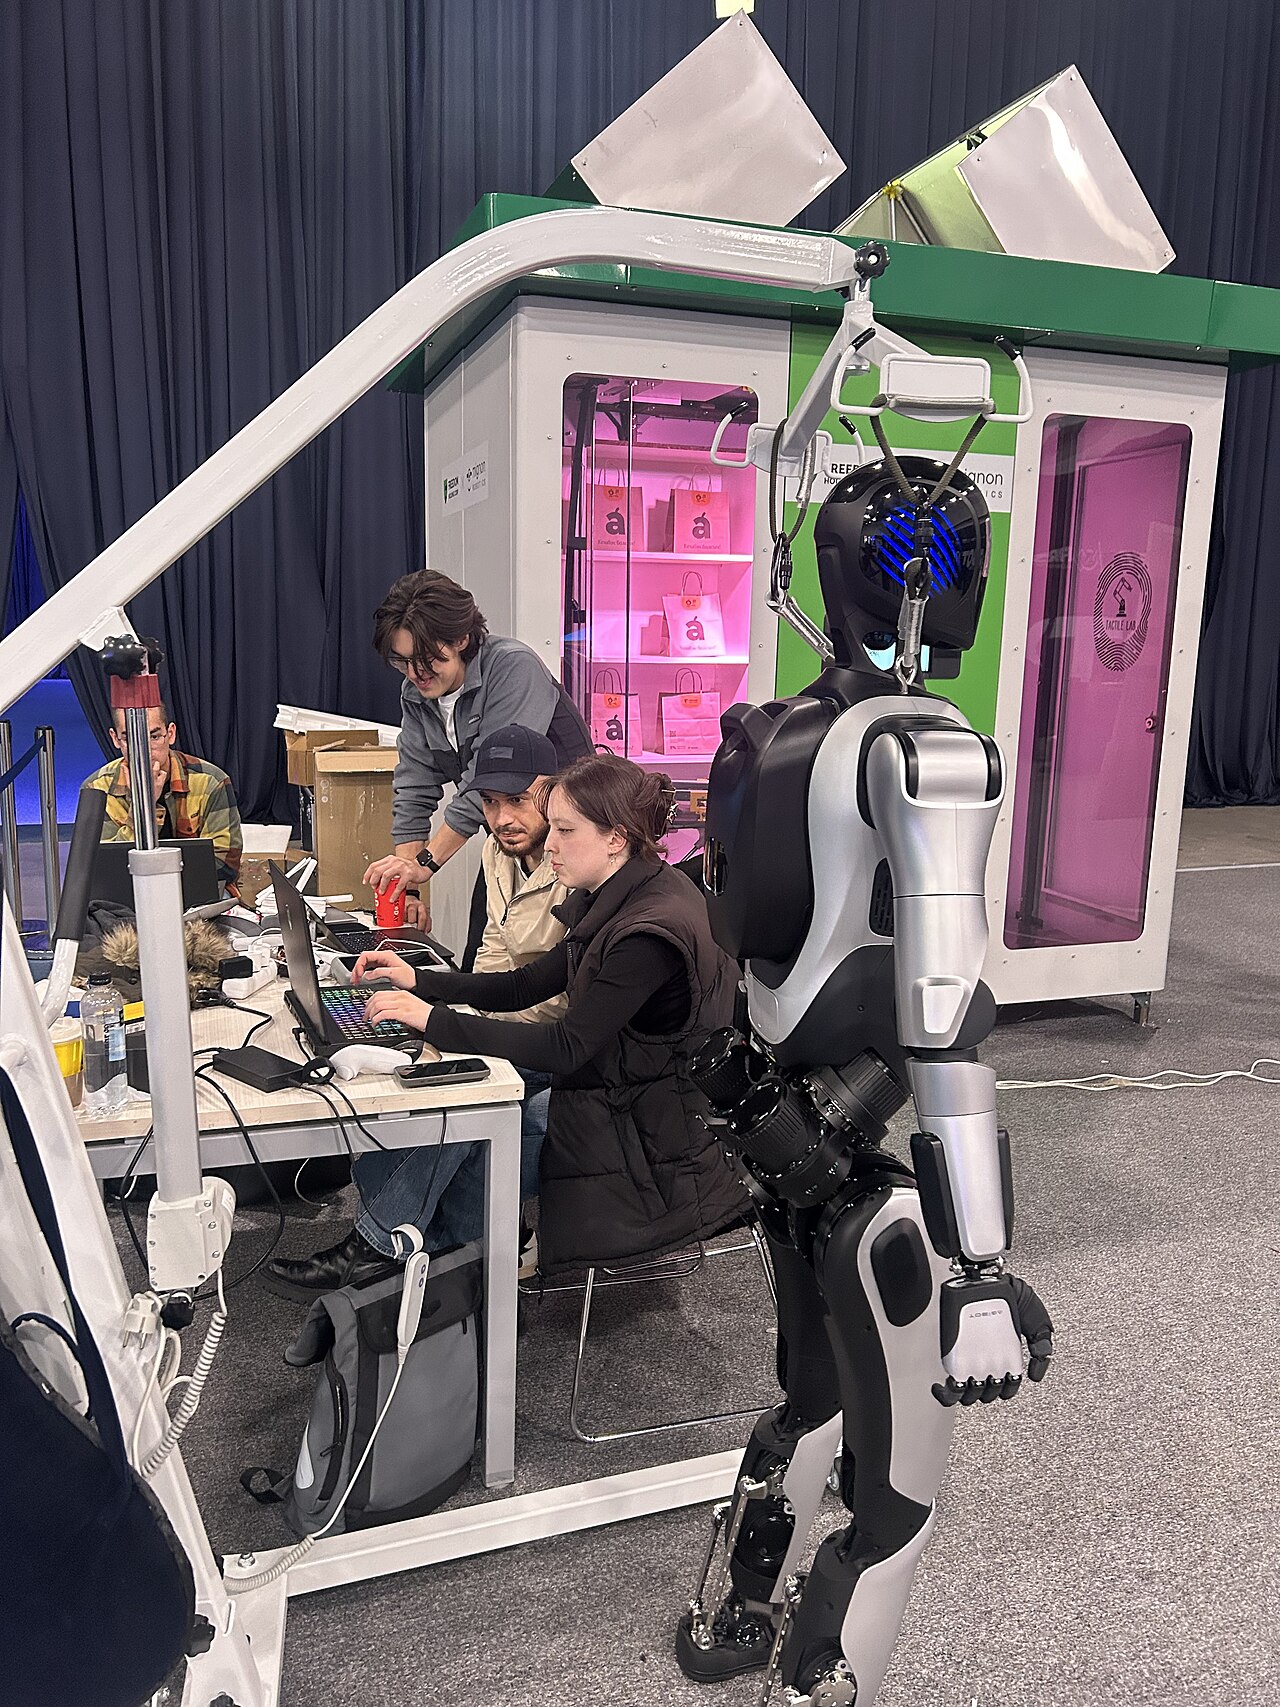
Copy the physics.
Train the possibility.
A convincing world is more than what you see. It is the weight of an object, the resistance of a surface, and what happens next.
01CAPTURE / REALITYBegin with the real.
Measure the conditions that shape behavior: mass, friction, compliance, fluid density and sensor noise.
02REBUILD / SIMULATIONKeep the consequences.
Reconstruct contact, deformation and state changes. Give each interaction a physical response, beyond its visual appearance.
03TRAIN / TRANSFERReturn to reality.
Explore variations before deployment. Train a policy against the surprises it will encounter when simulation gives way to the world.