
Less abstraction.
More interaction.
Look closer. Change a condition. Follow its consequence. Explore the ideas behind physical world simulation.
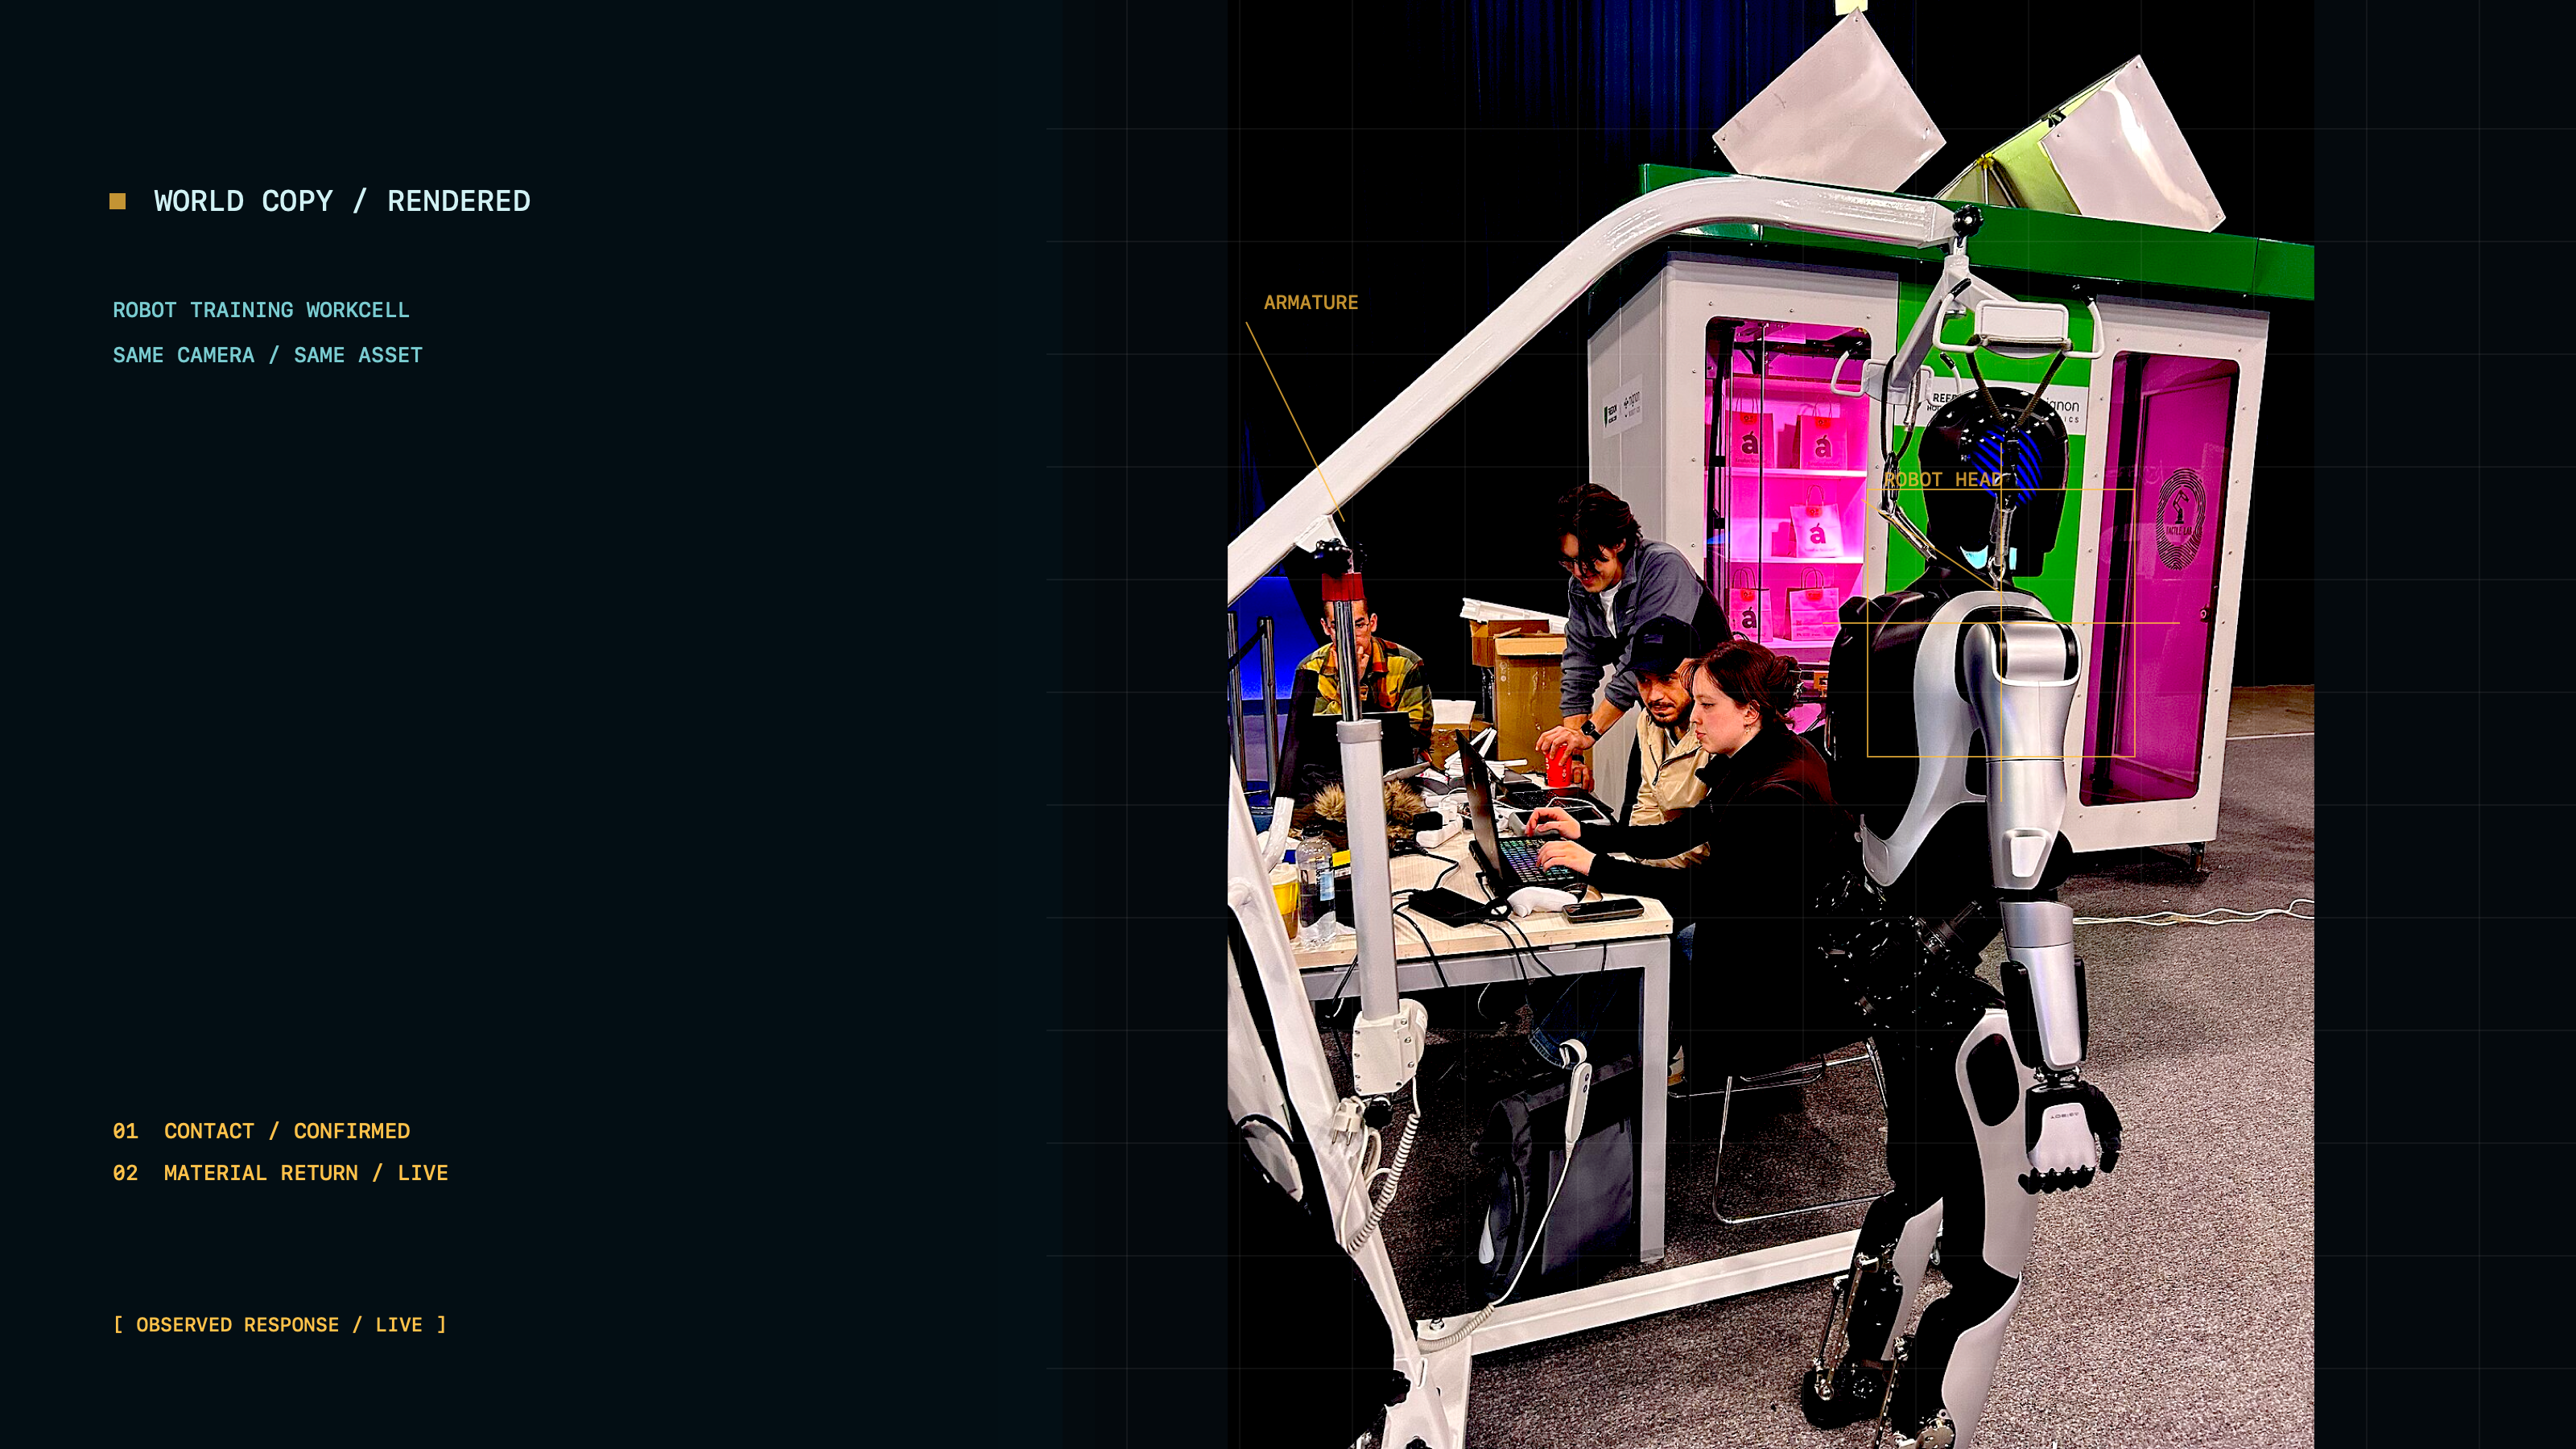
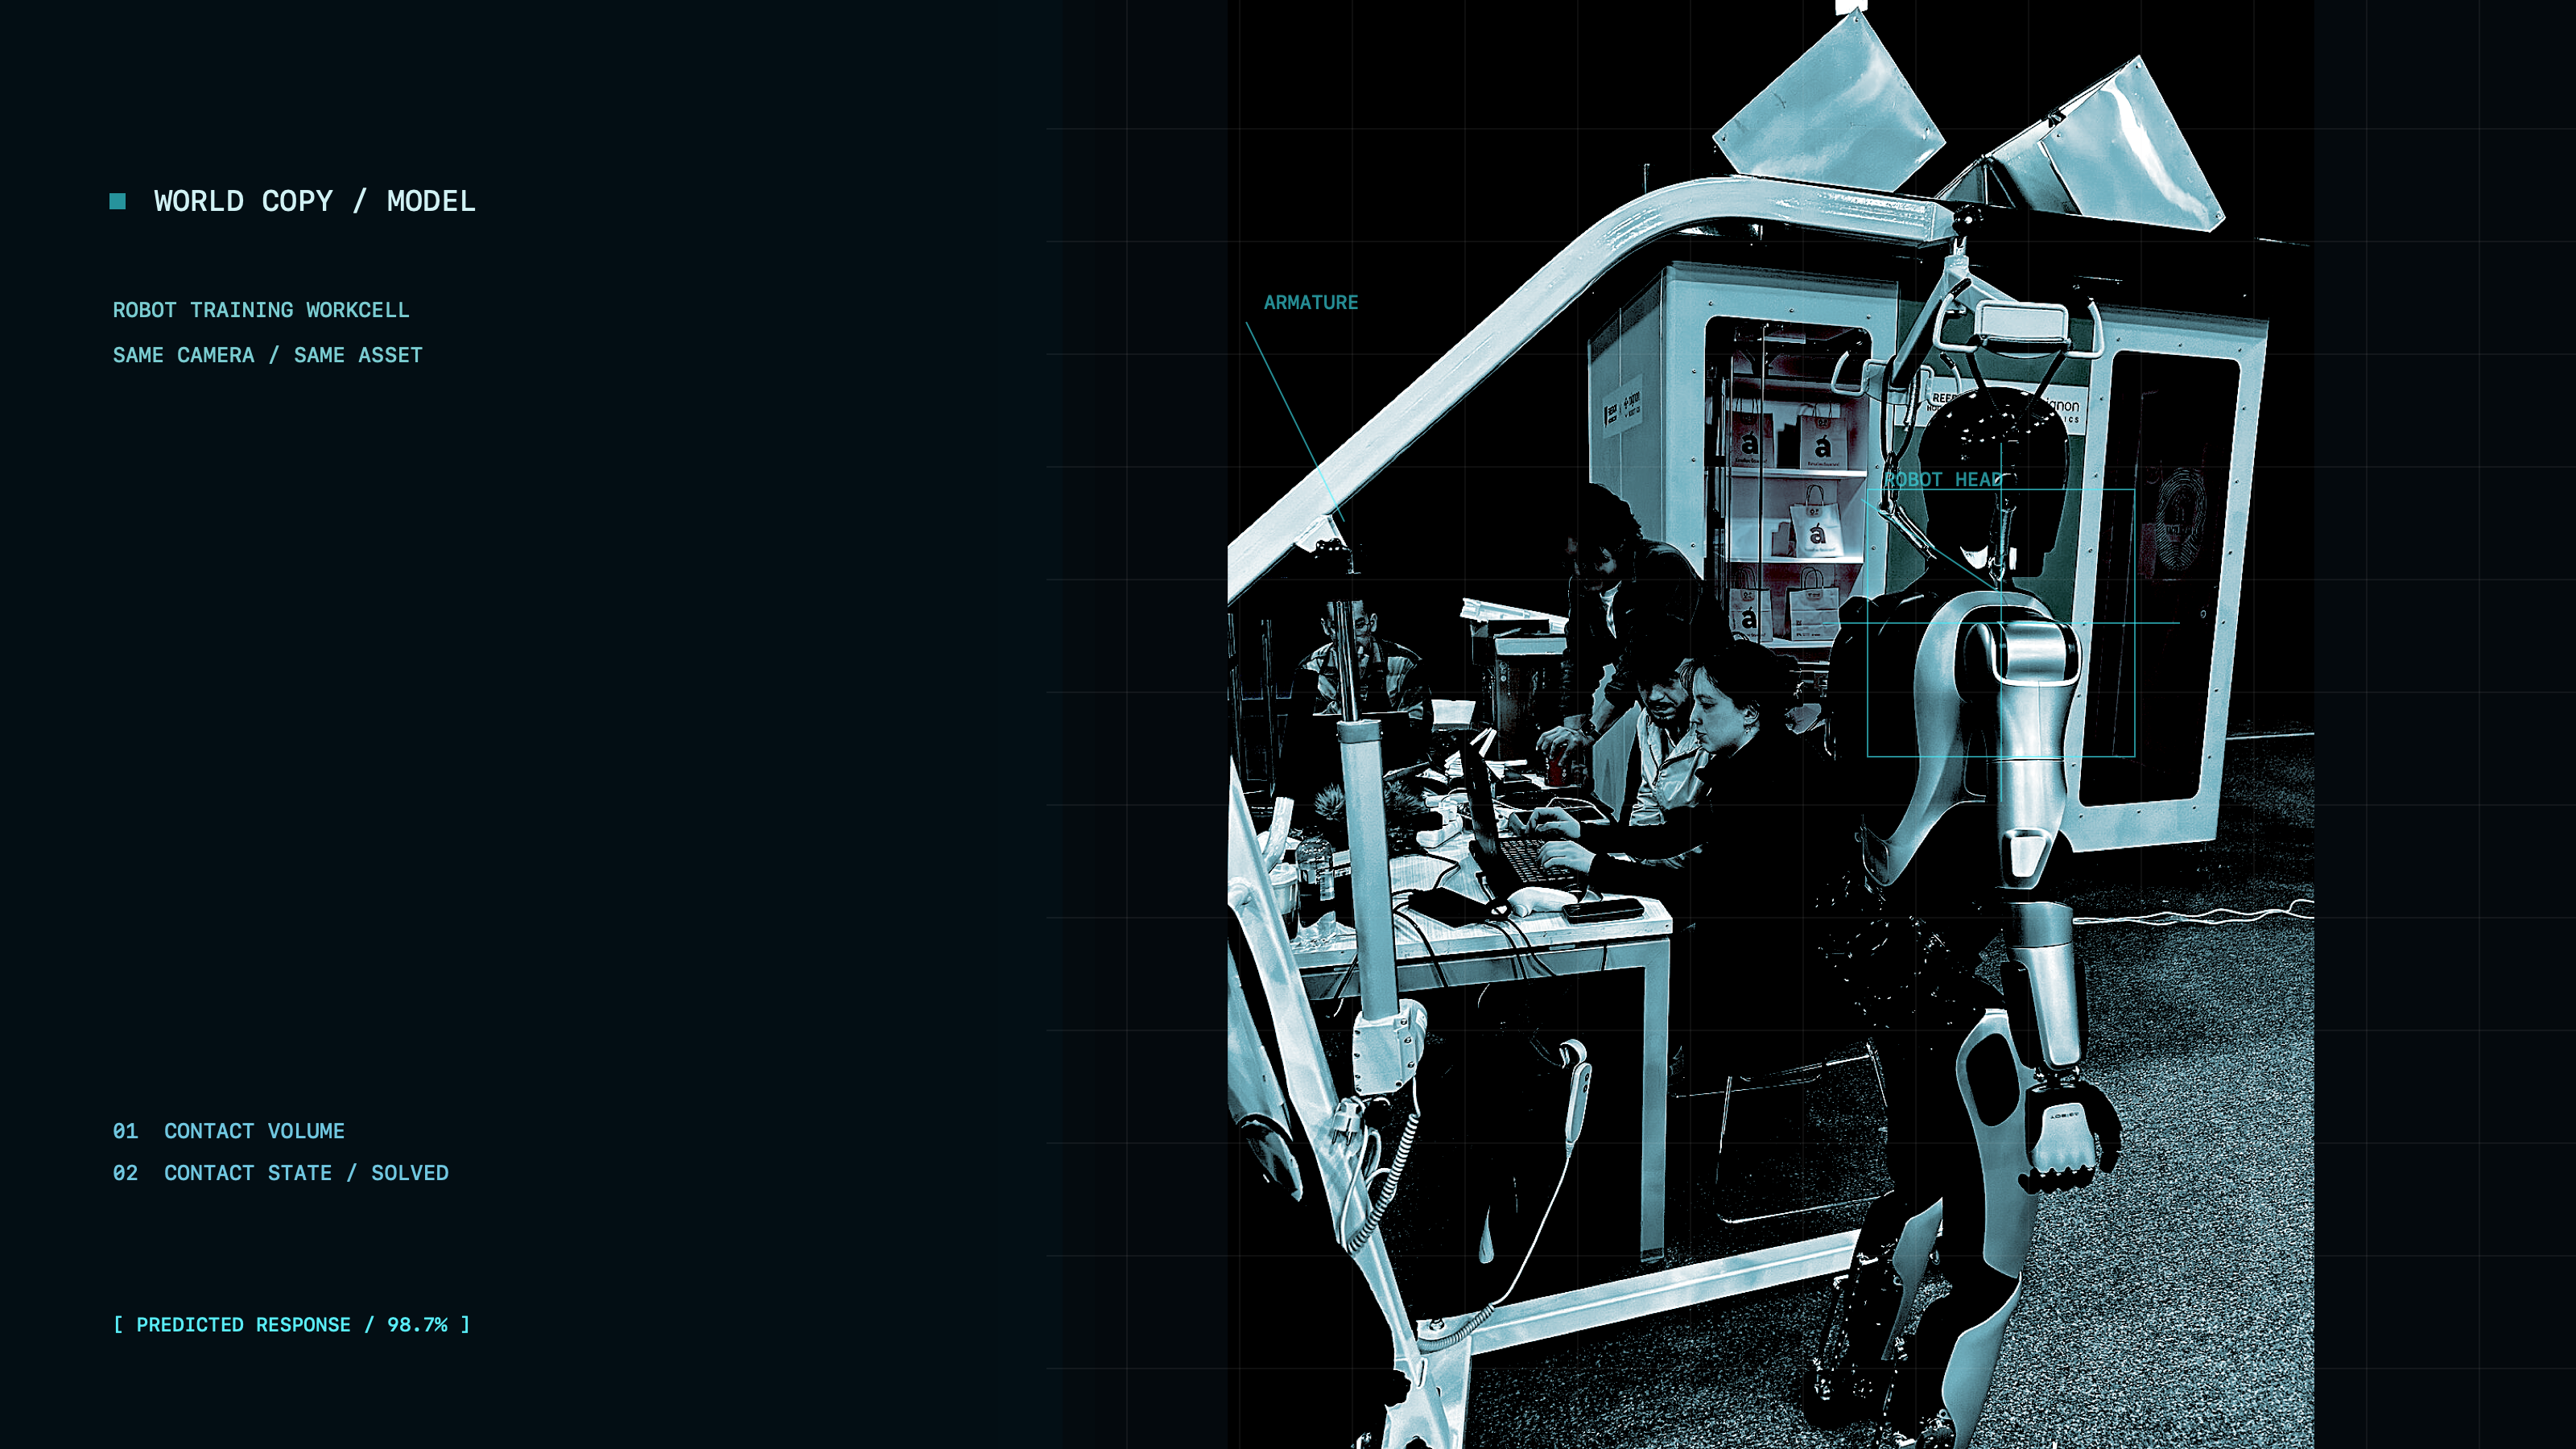 MODEL ↔ OBSERVATION
Two readings. One world.
Explore the space between a model and its rendered counterpart.
Inspect the twin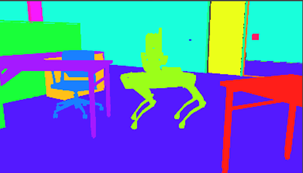 THE WORLD AS DATA
Through a machine’s eyes.
Read the same scene through aligned perception channels.
Explore the signalsLeave an impression.
Change the force. Place a contact. Watch the field respond.
Enter the contact fieldThe model is not
the world.
One workcell, two visual treatments. Move the boundary to inspect how a model and a rendered observation describe the same scene.
One world.
Many ways to see.
Appearance is one channel. Object identities are another. Explore how a shared scene becomes structured information for a robot.
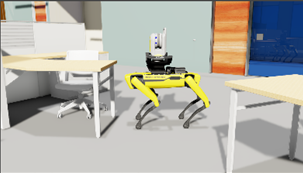
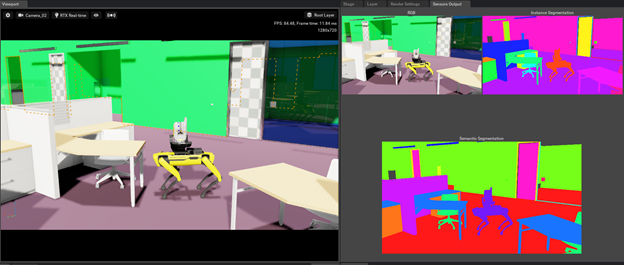
Teach what may change.
Vary the surroundings. Keep the task in focus.
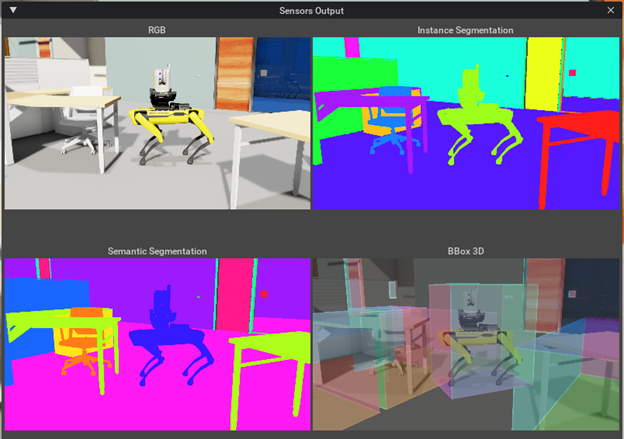
Keep the signals together.
Turn one scene into complementary observations.
A world that
pushes back.
Small actions leave a trace. Adjust the force, choose a material response, and place a contact in the field.
EXPERIMENT CONTROLS
An illustrative interaction study.
Explore response, not a measured solver output.
TOUCH THE FIELD